




Plastic Deformation at Microscale
Plastic Deformation at Microscale describes plastic deformation at microscale as a practical tribology topic: how surfaces interact, how friction, wear, lubrication, material response, and operating environment influence performance, and what engineers should check when applying the concept in real machines or laboratory tests.
- Core idea: plastic deformation at microscale should be interpreted as a system-level contact problem, not as an isolated material property.
- Engineering relevance: load, speed, temperature, surface roughness, chemistry, and lubrication regime can change the observed behavior.
- Good practice: combine measurements with surface inspection and clear reporting of test conditions.
- Failure prevention: use the topic to identify risks early, compare alternatives, and improve reliability.
Table of Contents
What is Plastic Deformation at Microscale?
Plastic Deformation at Microscale is part of the wider study of friction, wear, contact mechanics, materials, and lubrication. In practical use, the term is most useful when it is connected to a defined contact pair, surface condition, operating load, motion type, and environment.
For engineers, plastic deformation at microscale is not only a definition. It is a way to ask which mechanisms control performance at an interface: elastic or plastic deformation, adhesion, abrasion, fatigue, chemical film formation, lubricant starvation, debris generation, or changes in surface topography.
Why Plastic Deformation at Microscale matters in tribology
Plastic Deformation at Microscale matters because small changes at the surface can produce large changes in efficiency, temperature, noise, lifetime, and failure risk. A contact that appears acceptable under one load, speed, or lubricant can behave very differently when the regime shifts from full-film lubrication to mixed or boundary lubrication.
| Question | Why it matters |
|---|---|
| What materials and surfaces are in contact? | Hardness, roughness, coating, oxide layers, and chemistry influence friction and wear. |
| What motion occurs? | Sliding, rolling, reciprocating, impact, and vibration activate different damage mechanisms. |
| What lubrication regime is present? | Boundary, mixed, hydrodynamic, and elastohydrodynamic regimes produce different surface separation and film behavior. |
| What environment is involved? | Temperature, humidity, vacuum, contamination, and reactive species can strongly change tribochemical response. |
Engineering factors to consider
- Contact stress and geometry: estimate nominal and local contact pressure, including asperity-scale effects where relevant.
- Surface topography: measure roughness, waviness, texture direction, and surface defects before and after testing.
- Lubricant selection: consider viscosity, additives, supply method, contamination, and compatibility with materials.
- Thermal conditions: frictional heating can change viscosity, hardness, oxidation rate, and tribofilm formation.
- Running-in: early surface adaptation may control the later steady-state response.
- Debris control: wear particles can become a third body, accelerating abrasion or changing friction.
Measurement and interpretation
When evaluating plastic deformation at microscale, report the test configuration clearly: specimen geometry, material grade, surface roughness, lubricant, load, speed, temperature, duration, environment, and repeat count. Tribology results are often system-dependent, so a coefficient of friction, wear scar, or lifetime result should not be treated as a universal property without context.
Useful measurements include friction trace, wear volume or wear rate, surface profilometry, optical or electron microscopy, hardness, lubricant condition, and chemical surface analysis where tribofilms or oxidation are expected.
Detailed background and source material
What is plastic deformation?
[avatar user=”Nilgoon Irani” size=”original” align=”left” link=”linkedin.com/in/nilgoonirani“] The article was created by Dr. Nilgoon Irani[/avatar]
Plastic deformation, in general, can be defined as a permanent deformation, a non-reversible change in the geometry of a body under applied stresses (forces). For example, if hit sufficiently hard by a piece of rock or hail, a car body made of metal gets a dent (irreversible deformation). On the other hand, rubber is an example of a material which exhibits highly elastic behaviour: you can stretch it to a high degree, but once the force is released rubber returns to its original shape. Plastic deformation occurs at a certain critical stress (force) beyond which the deformation is irreversible. This transition is known as yield. Plastic deformation may occur in most engineering materials including metals, soils, rocks, concrete, foams. However, in different materials, the mechanisms responsible for plastic deformation can be different: dislocation motion, vacancy motion, twinning, phase transformation, or viscous flow of amorphous materials.
Plastic deformation in metals
In metals, room temperature plastic deformation occurs as a consequence of the collective motion of dislocations gliding on specific slip planes. In continuum plasticity formulations, the effect of individual dislocations is ignored and hence, such descriptions are not suitable for applications such as the development of devices with characteristic length scales in the micrometre range (e.g. MEMS).
In Fig. 1, the various relevant scales (macro- to nano-scale) determining the response of metals during plastic deformation are demonstrated. As one can observe at macro-scale the plastic zone is governed by continuum plastic flow (Fig. 1(b)). Inside this plastic region, the material is polycrystalline with the plastic deformation being different in different grains (Fig. 1(c)). By magnifying this region, it can be recognized that at the micro-scale plastic deformation occurs as a consequence of the collective motion of dislocations gliding on specific slip planes (Fig. 1(d)). It is the mobility of these dislocations that gives rise to plastic flow at stress levels relatively low compared to the theoretical strength (see [1]). Finally, at the nano-scale, the atomic arrangement of the material is revealed (Fig. 1(e)). At this scale, dislocations are shown to be irregularities within the crystal structure.
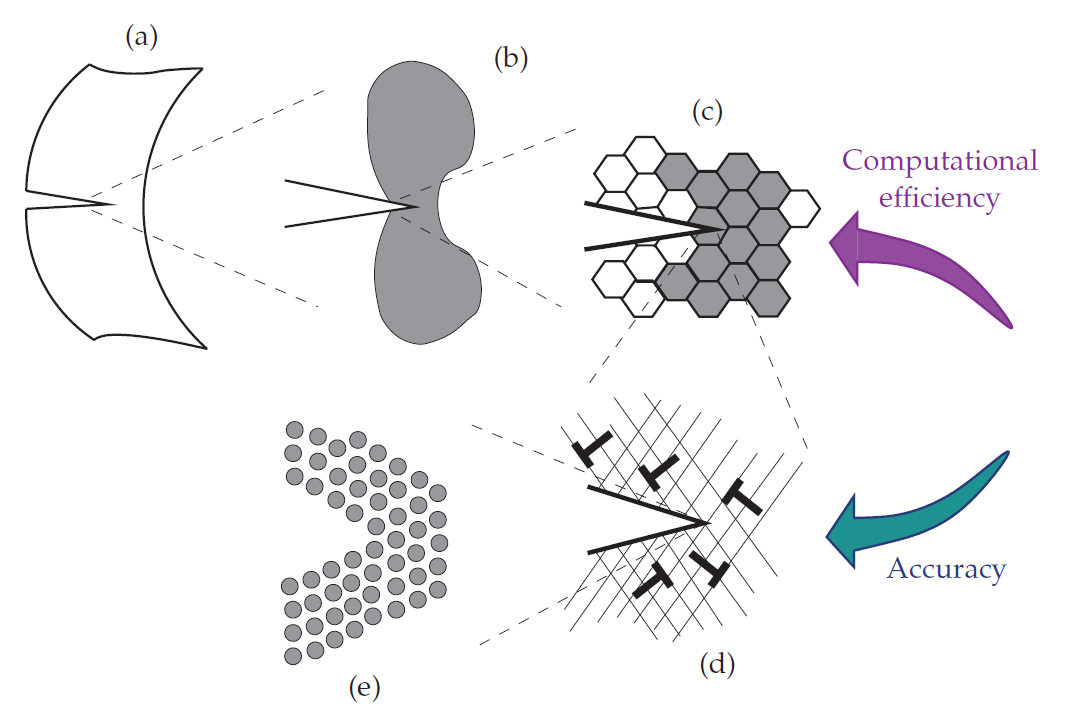
Figure 1: Description of plastic deformation in metals at various length scales. (a) A material under fracture. (b) Phenomenological continuum plasticity (macro-scale). (c) Crystal plasticity (meso-scale). (d) Discrete dislocation plasticity (micro-scale). (e) Atomistic simulations (nano-scale) (reproduced from [2]).
Figure 1 illustrates that as one approaches smaller length scales the amount of the physics captured in these models increases, yet this is achieved by the expense of heavier and higher calculation times. The difference between the plasticity models at various scales is based on how they describe dislocation motions and interactions:

- Continuum and (ploy)crystal models (macro- and meso-scales): These models consist of phenomenological continuum and crystal plasticity theories which consider the average motion of groups or densities of dislocations. These theories are employed at the size scale of Figs. 1(a)-1(c), i.e. when the length scale of the specimen exceeds the size of the individual grains or when the number of dislocations in the material is large. For describing plasticity at this scale accounting for dislocation densities will suffice and there is no need to consider individual dislocations. Examples of these models can be found in Groma (1997) [3] and Fleck et al. (1994) [4].
- Discrete dislocation models (micro-scale): These methods describe plastic flow in terms of the dynamics of large numbers of interacting discrete dislocations while taking into account individual behaviour of every dislocation inside crystals (Fig. 1(d)). As a result, these frameworks may give an accurate description of the material behaviour when specimen size gets within the micrometre range. Hence, these models are mainly employed to enhance the understanding of defect interactions and also to provide better assumptions for the parameters used in meso-scale plasticity models. Examples of these methods include Zbib et al. (2002) [5], van der Giessen and Needleman (1995) [6], Irani et al. [7], and Lepinoux and Kubin (1987) [8].
- Atomistic models (nano-scale): The discrete dislocation based methods require governing laws for individual dislocations and their short-range interactions with each other. The constitutive laws at the nano-scale are difficult to obtain experimentally and therefore, they are usually investigated by atomistic models at the size scale of Fig. 1.1(e). For examples of these methods see Bernstein et al. (2009) [9], and Curtin and Miller (2003) [10].
Here, as an example of micro-scale plasticity techniques, the discrete dislocation plasticity (DDP) of van der Giessen and Needleman (1995) [6] is presented. In this framework, plastic deformation and flow are described by the nucleation and glide of discrete edge dislocations. Here, a brief and general summary of the DDP formulation in a small strain setting is provided:
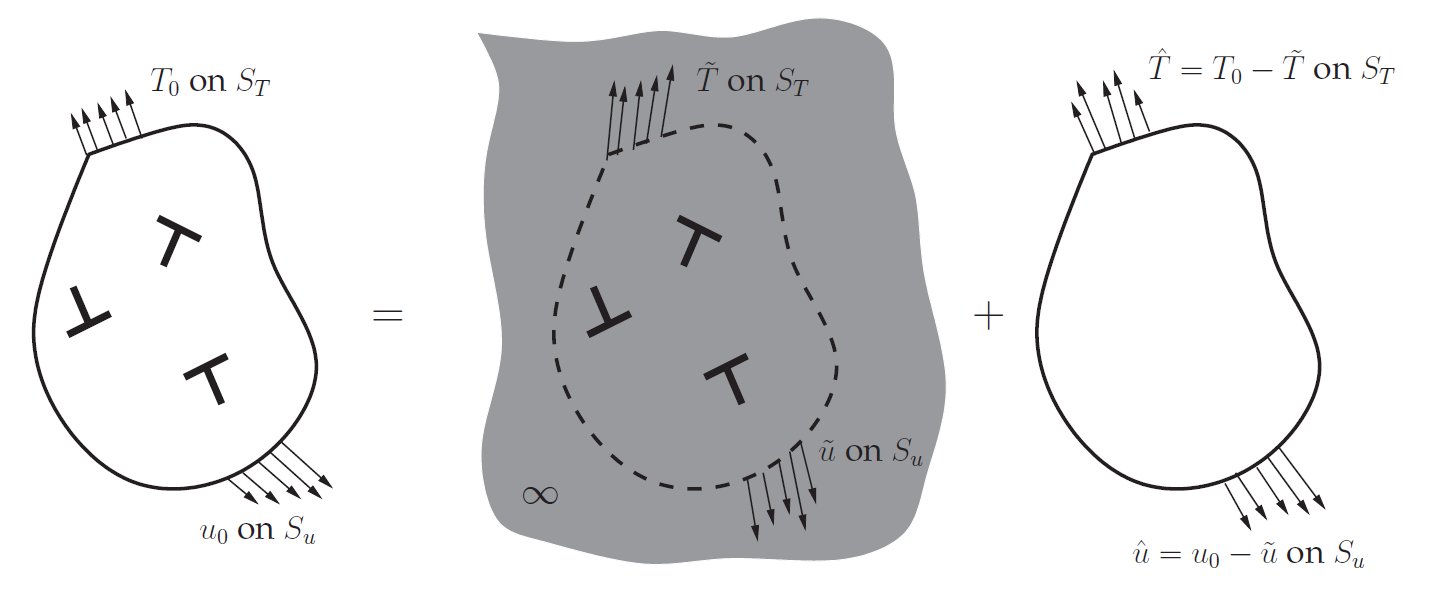
Figure 2: Decomposition of the boundary value problem: summation of the dislocation fields, the (˜) fields, and complementary fields, the (ˆ) fields. Here, the inverted T symbols stand for an edge dislocation. For more details see van der Giessen and Needleman (1995) [6].
Consider a two-dimensional body under plane strain conditions such that at time t, the body contains N edge dislocations, with the dislocations being represented as line singularities in an elastic medium. In this method, to obtain the solution, the problem is decomposed in two additive parts and the field quantities are computed using superposition (see Fig. 2). First, the singular (˜) fields associated with the N dislocations are calculated analytically. In this method, typically the analytically calculated dislocations fields in an infinite medium are used to represent the (˜) fields. Thus, these fields do not give the correct stress and displacement fields at the boundaries. This issue is solved by solving for a complementary problem, where both the boundary conditions and the dislocation fields are applied (see Fig. 2). Thus, the complementary problem is an elasticity boundary value problem with its boundary conditions changing as the dislocation structure evolves. One may solve the complementary problem by employing conventional finite element methods.
At the beginning of a calculation the crystal is stress- and dislocation-free. New dislocation pairs are generated by simulating Frank-Read sources. In two dimensions, this is mimicked by discrete point sources randomly distributed on the slip planes. These sources generate a dislocation dipole with their Burgers vectors aligned with the slip plane direction. This occurs when the magnitude of the Peach-Koehler force on a source exceeds a critical value for a certain time. Annihilation of two opposite signed dislocations on a slip plane occurs when they are within a material-dependent critical annihilation distance. The magnitude of the glide velocity along the slip direction of a dislocation is taken to be linearly related to the Peach-Koehler force. Obstacles to dislocation motion are modelled as points associated with a slip plane. The dislocations gliding on the slip plane of an obstacle, get pinned as they try to pass through this obstacle. Moreover, obstacles release the pinned dislocations when the Peach-Koehler force on the obstacle exceeds a critical value.
(a)
(b)
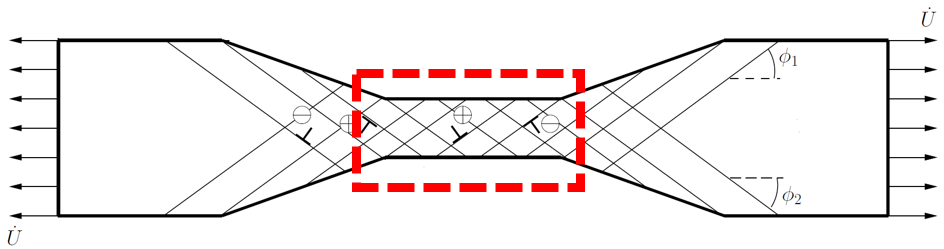
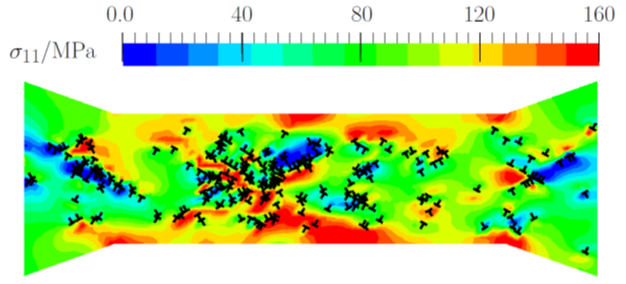
Figure 3: (a) Sketch of the uniaxial tension of a dog-bone specimen at the micro-scale with the window over which the dislocation distributions are shown in (b). The crystal is shown in the double slip configuration. (b) A snapshot of DDP predictions of the dislocation and tensile stress σ11 distributions [11].
Figure 3(a) demonstrates a metallic dog-bone specimen under tensile loading at the micro-scale. As it is shown, at this length-scale, we must treat the specimen as a crystalline material with discrete slip planes. Figure 3(b) illustrates that by using discrete dislocation plasticity we have been able to model the individual behaviour of every dislocation inside the crystal. As a result, we could account for both the stress enhancement due to organized dislocation structures and the stress relaxation arising from dislocation glide. For more information on this topic, the interested reader is referred to [12].
FAQs
What is Plastic Deformation at Microscale in simple terms?
Plastic Deformation at Microscale is a tribology topic used to understand how contacting surfaces behave under load, motion, lubrication, and environmental conditions.
Why is plastic deformation at microscale important for engineers?
It helps engineers diagnose friction and wear problems, choose materials or lubricants, design tests, and prevent surface-related failures.
How should plastic deformation at microscale be tested?
Testing should reproduce the relevant contact geometry, motion, load, speed, temperature, surface roughness, lubricant, and environment as closely as practical.
What should be reported with plastic deformation at microscale results?
Report materials, roughness, lubricant, load, speed, temperature, duration, environment, friction history, wear measurement method, and post-test surface observations.
See also
References and further reading
- Bhushan, B. Introduction to Tribology. Wiley.
- Stachowiak, G. W., and Batchelor, A. W. Engineering Tribology. Butterworth-Heinemann.
- Hamrock, B. J., Schmid, S. R., and Jacobson, B. O. Fundamentals of Fluid Film Lubrication. CRC Press.
- NIST resources for measurement, materials, and surface characterization.
Last updated: May 2026. Reviewed topic: Plastic Deformation at Microscale, tribological performance, measurement, and failure prevention.
References
- [1] https://en.wikipedia.org/wiki/Dislocation
- [2] van der Giessen, E. and Needleman, A. (2003). Dislocation plasticity effects on interfacial fracture. Interface Science, 11(3):291–301.
- [3] Groma, I. (1997). Link between the microscopic and mesoscopic length-scale description of the collective behavior of dislocations. Physical Review B, 56(10):5807–5813.
- [4] Fleck, N. A., Muller, G. M., Ashby, M. F., and Hutchinson, J. W. (1994). Strain gradient plasticity: theory and experiment. Acta Metallurgica et Materialia, 42(2):475–487.
- [5] Zbib, H. M., de la Rubia, T. D., and Bulatov, V. (2002). A multiscale model of plasticity based on discrete dislocation dynamics. Journal of Engineering Materials and Technology, 124:78–87.
- [6] van der Giessen, E. and Needleman, A. (1995). Discrete dislocation plasticity: a simple planar model. Modelling and Simulation in Materials Science and Engineering, 3:689–735.
- [7] N. Irani , J.J.C. Remmers and V.S. Deshpande, 2015. Finite strain discrete dislocation plasticity in a total Lagrangian setting. Journal of the Mechanics and Physics of Solids, 83 (2015), 160–178.
- [8] Lepinoux, J. and Kubin, L. P. (1987). The dynamic organization of dislocation structures: a simulation. Scripta metallurgica, 21(6):833–838.
- [9] Bernstein, N., Kermode, J. R., and Csanyi, G. (2009). Hybrid atomistic simulation methods for materials systems. Reports on Progress in Physics, 72(2):026501
- [10] Curtin, W. A. and Miller, R. E. (2003). Atomistic/continuum coupling in computational materials science. Modelling and simulation in materials science and engineering, 11(3):R33–R68.
- [11] Irani, N., Remmers, J. J. C., Deshpande, V. S., (2017). Finite versus small strain discrete dislocation analysis of cantilever bending of single crystals. Acta Mechanica Sinica, 33.4: 763-777.
- [12] Irani, N., 2016. Finite strain discrete dislocation plasticity: applications and new developments. Eindhoven University of Technology, The Netherlands.
- [13] Irani, N., Remmers, J. J. C., Deshpande, V. S., (2017). A discrete dislocation analysis of hydrogen-assisted mode-I fracture. Mechanics of Materials 105: 67-79.
0 Comment