




Conical Indenter
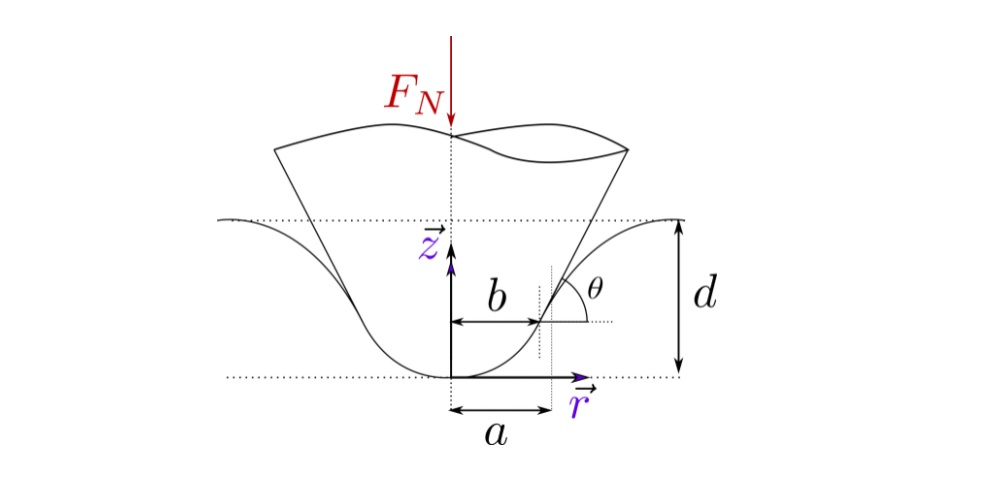
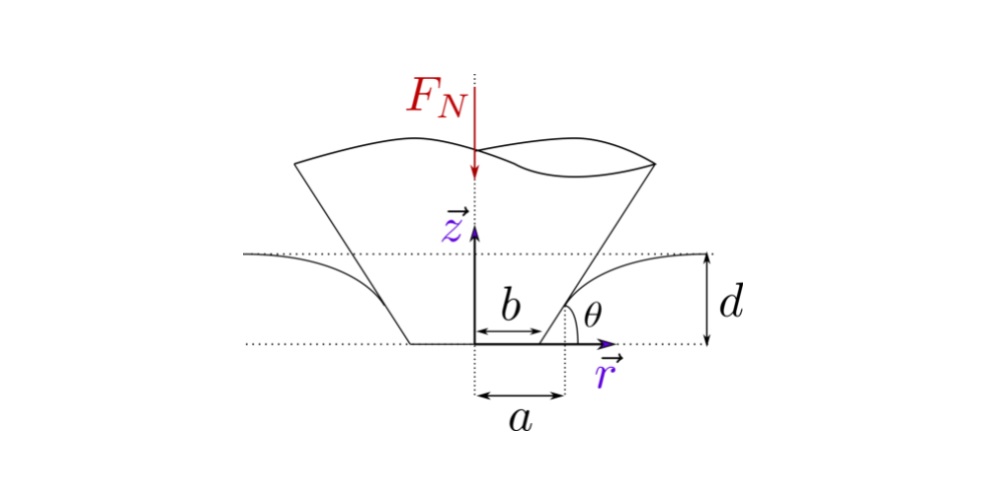
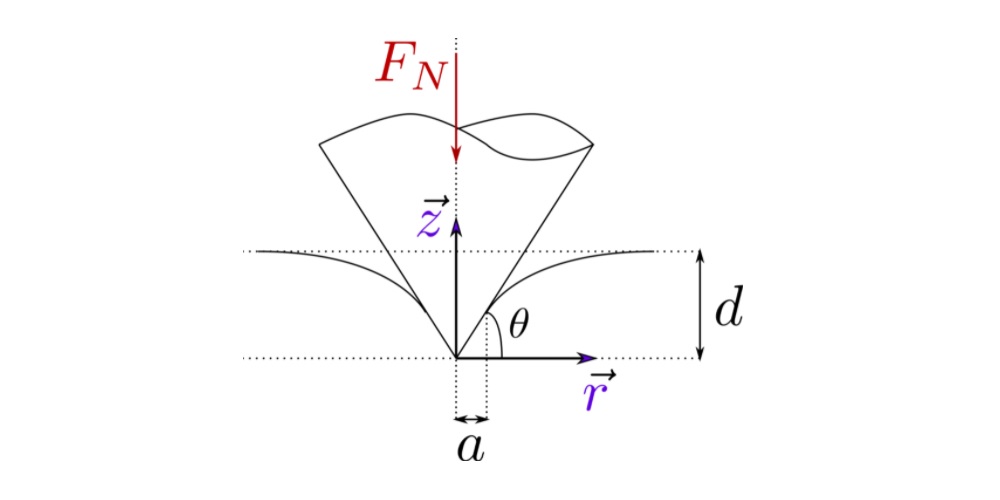
The conical intender is characterized by its inclination angle  . After applying a rigid body motion
 (resulting in normal load
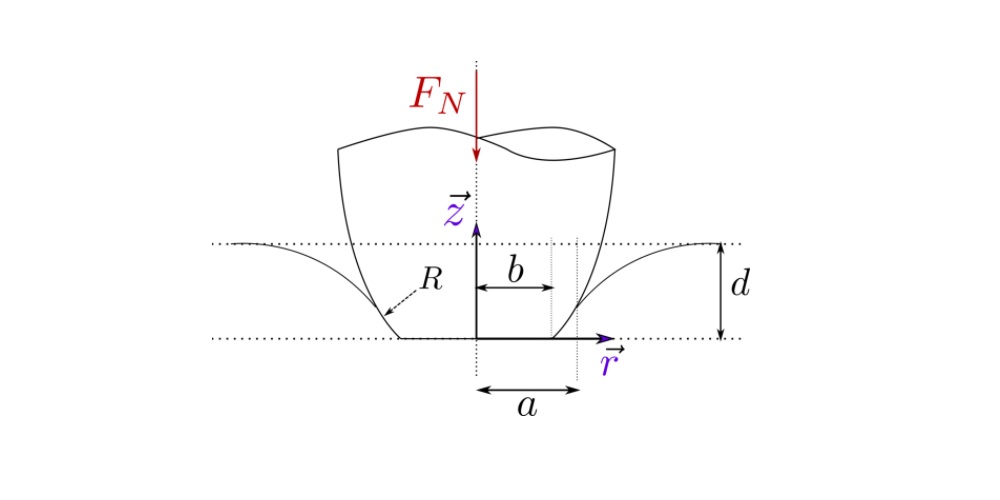
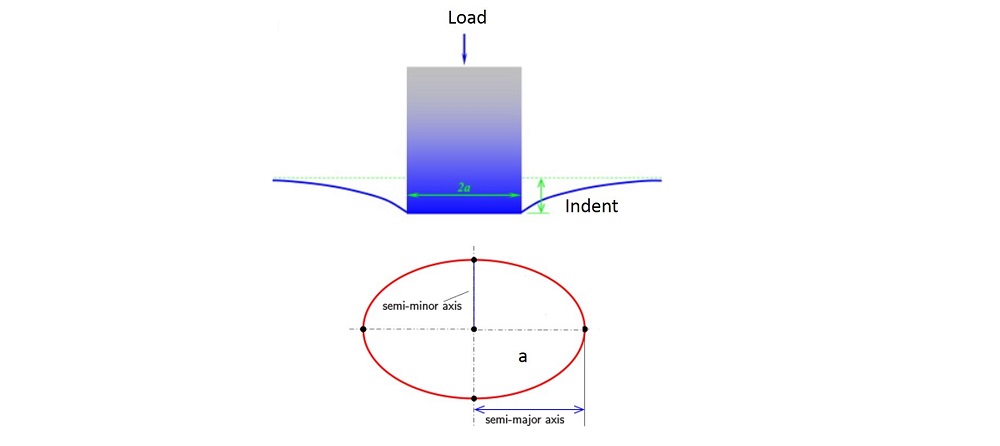
 ) on an elastic substrate, the intender deforms the substrate and creates elastic deformation and effective contact radius
 as shown in the figure.
Displacement depth , inclination angle and contact radius are all related to other geometrically. The contact radius can be calculated using the relation:
(1) 
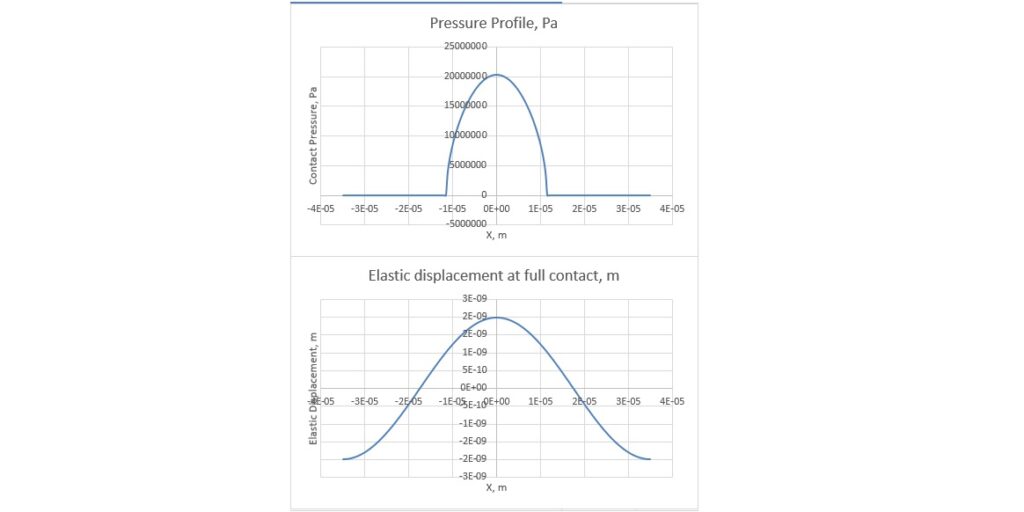
The profile of the stress  and the displacement
 are determined by the formulas below ([1]):
(2) 
where  is the average pressure which is given by the equation:
(3) 
while  is the elasticity of the substrate or the conical intender as well.
These formulas are restricted to relatively small values.
Definitions:
Poisson’s ratio of the substrate  dimensionless,
Young’s modulus of elasticity  of the substrate, [Pa],
Equivalent elastic constant  , [Pa],
Normal load , [N]